Engineering project
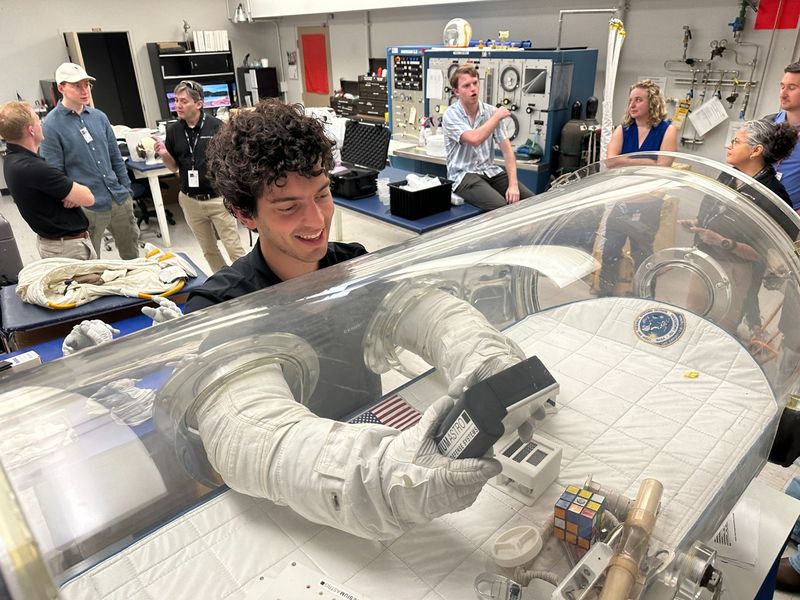
Lunar navigation device
A glove-operable prototype built at CesiumAstro, with a capstone engineering model underway.
Explore project →Engineering & personal work
Hardware, robotics and the decisions behind them.
Engineering project
A glove-operable prototype built at CesiumAstro, with a capstone engineering model underway.
Explore project →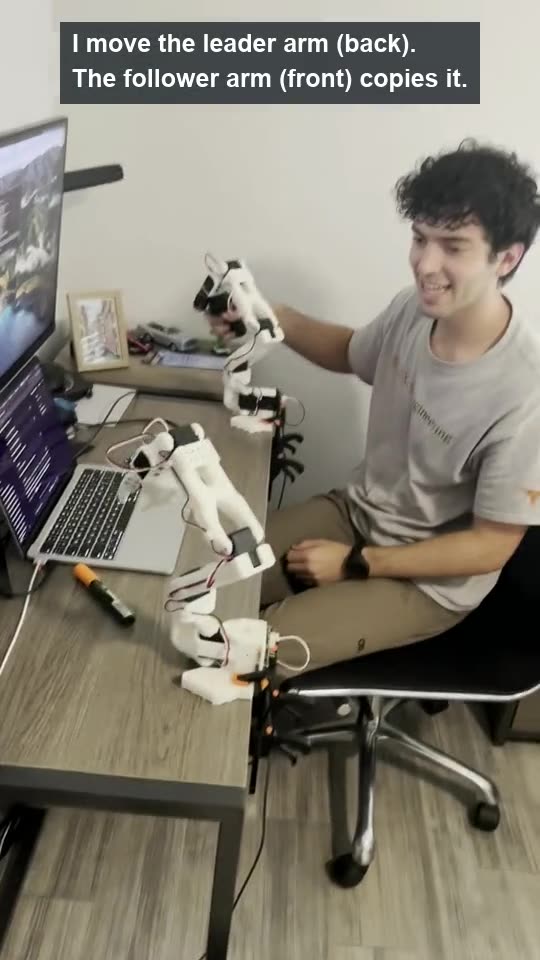
Engineering project
A leader–follower platform for recording demonstrations and studying objective inference.
Explore project →Engineering project
A microsimulation for studying local coordination among connected and human-driven vehicles.
Explore project →Course project · Fall 2025
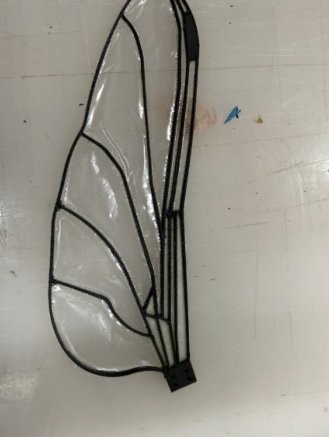
At the University of Edinburgh, I owned the biomimetic structural design of a 250 mm wing that measured about 85:1 base-to-tip stiffness in point-load tests, against roughly 100:1 for Aeshna dragonflies. It was not flight-tested.
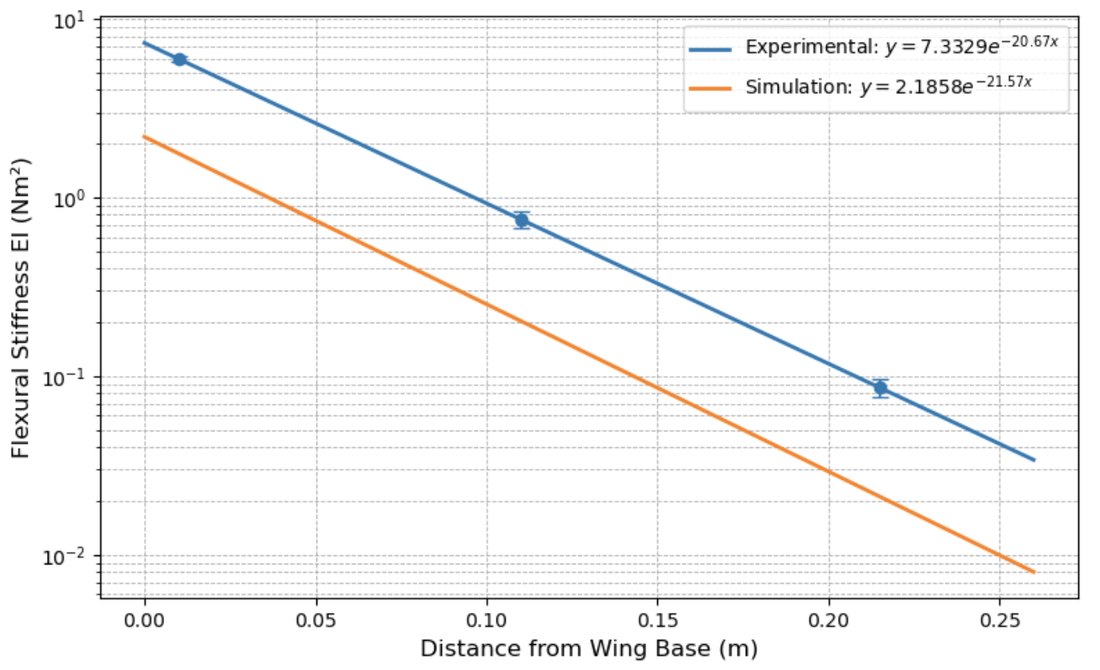
| Iteration | Veins | Base:tip EI |
|---|---|---|
| 1 | PLA, 1.5 mm | 2.0 |
| 2 | Onyx, 1.5 mm | 38.4 |
| 3 | Onyx + CF, 1 mm | 65.2 |
| 4 (built) | Onyx + CF, 1.5 mm | 104.9 |
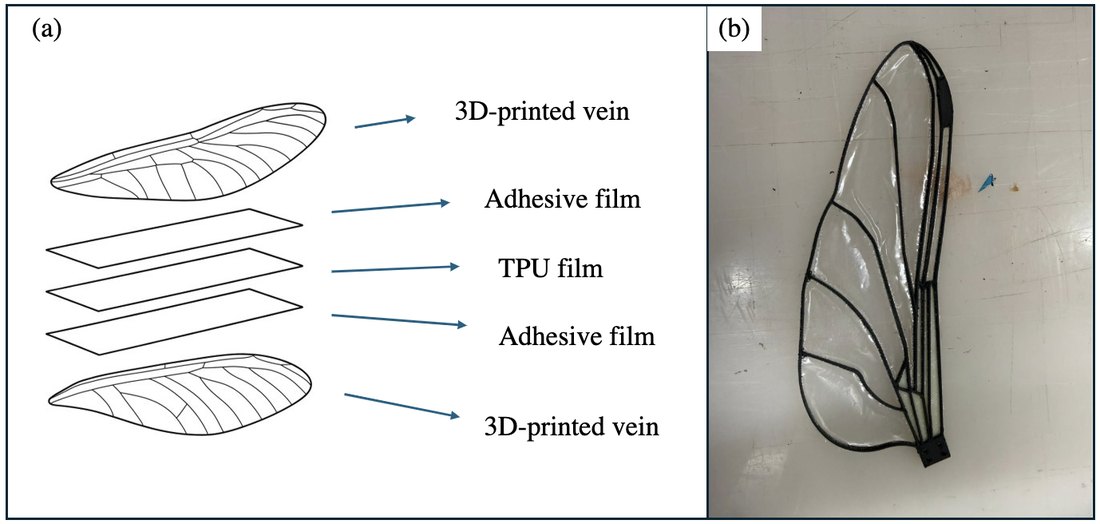
Modal analysis put the first bending mode at 12.1 Hz and the first torsional mode at 26.0 Hz, around a 20 Hz flapping target for a ~100 g micro air vehicle.
I also contributed to the analysis.
Personal · in progress
A tracking mount with a 100:1 harmonic gearbox and a 3:1 belt stage, 300:1 overall. I designed the housing and belt tensioning and ran the telescope-load calculations. Motor control and tracking come next.
Personal build
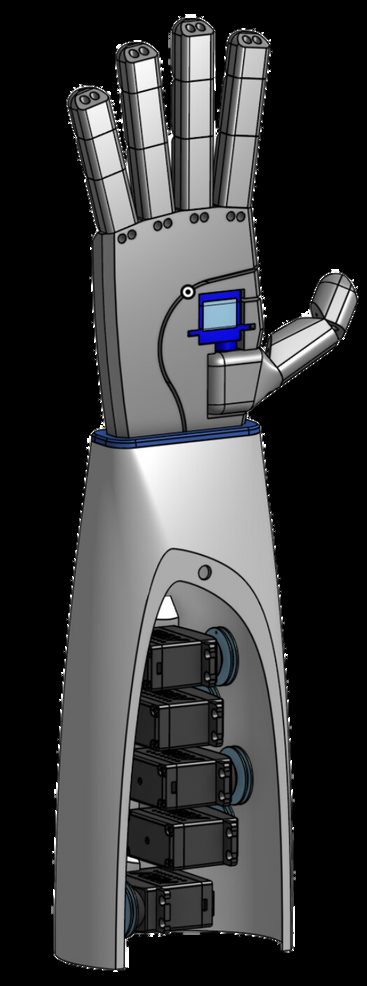
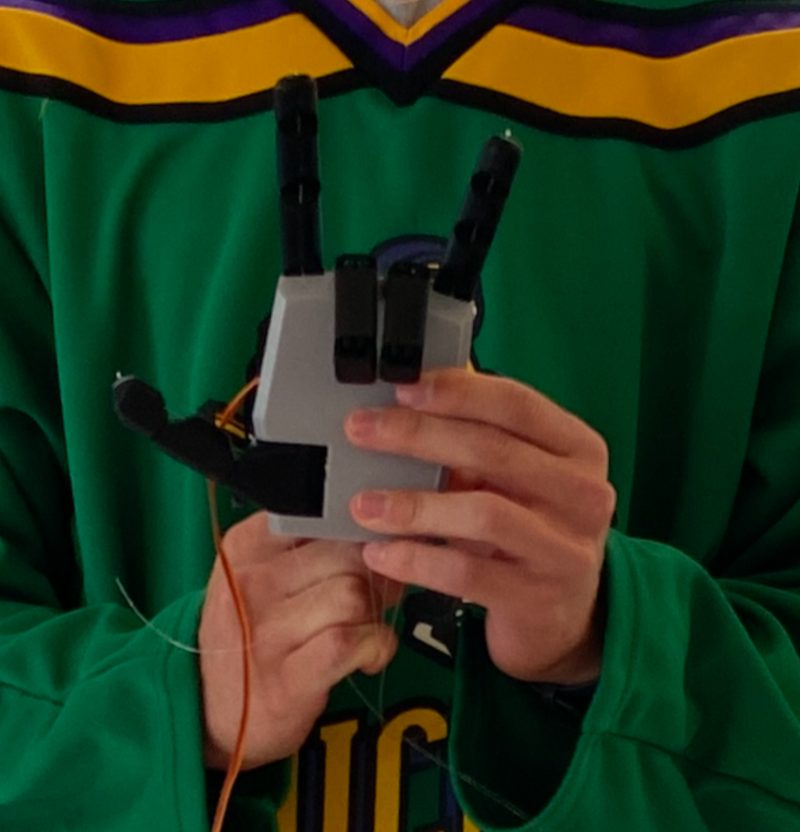
A fully 3D-printed hand modeled in Onshape from my own hand’s dimensions. Servos in the forearm run on C++, and Python/OpenCV hand tracking lets it mirror my movements.
Personal build
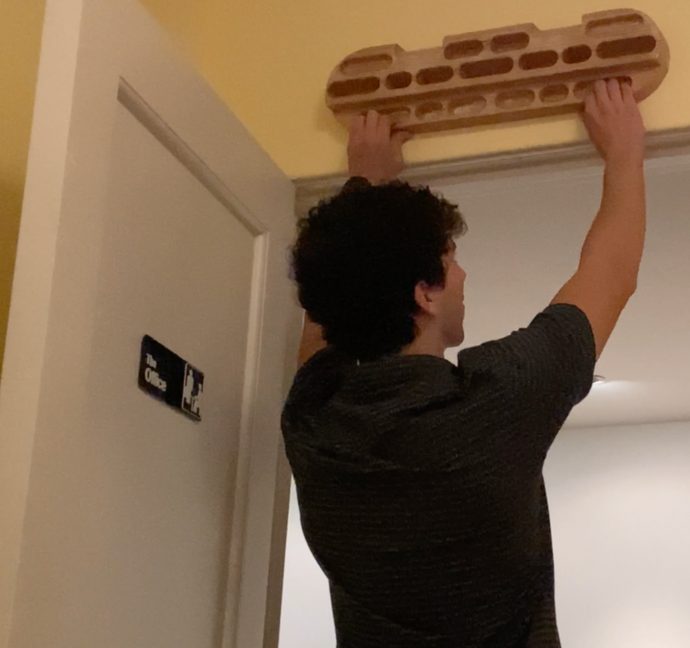
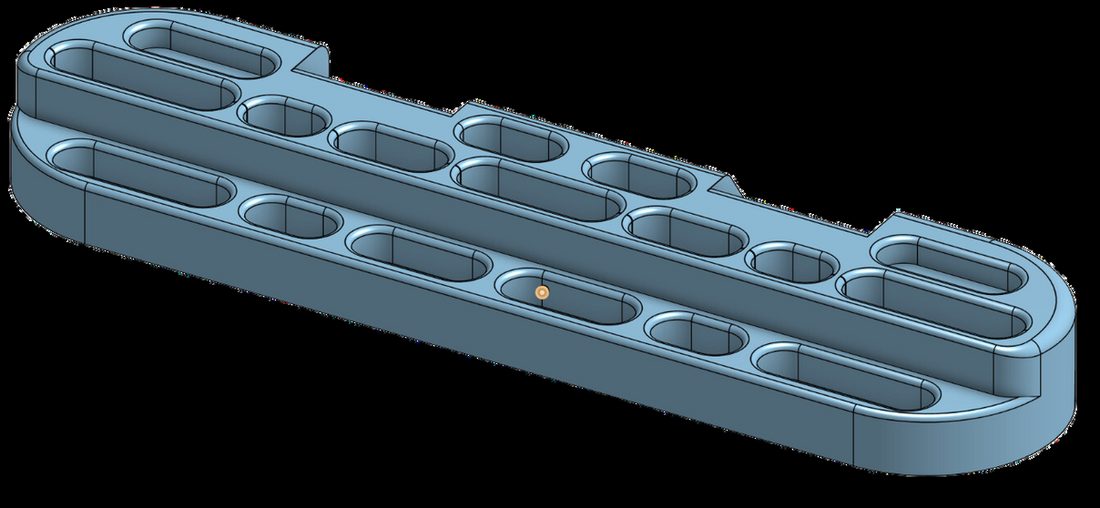
A cheaper climbing hangboard with holds of several depths, modeled in Onshape and routed from wood with Fusion 360 CAM toolpaths.
Personal builds
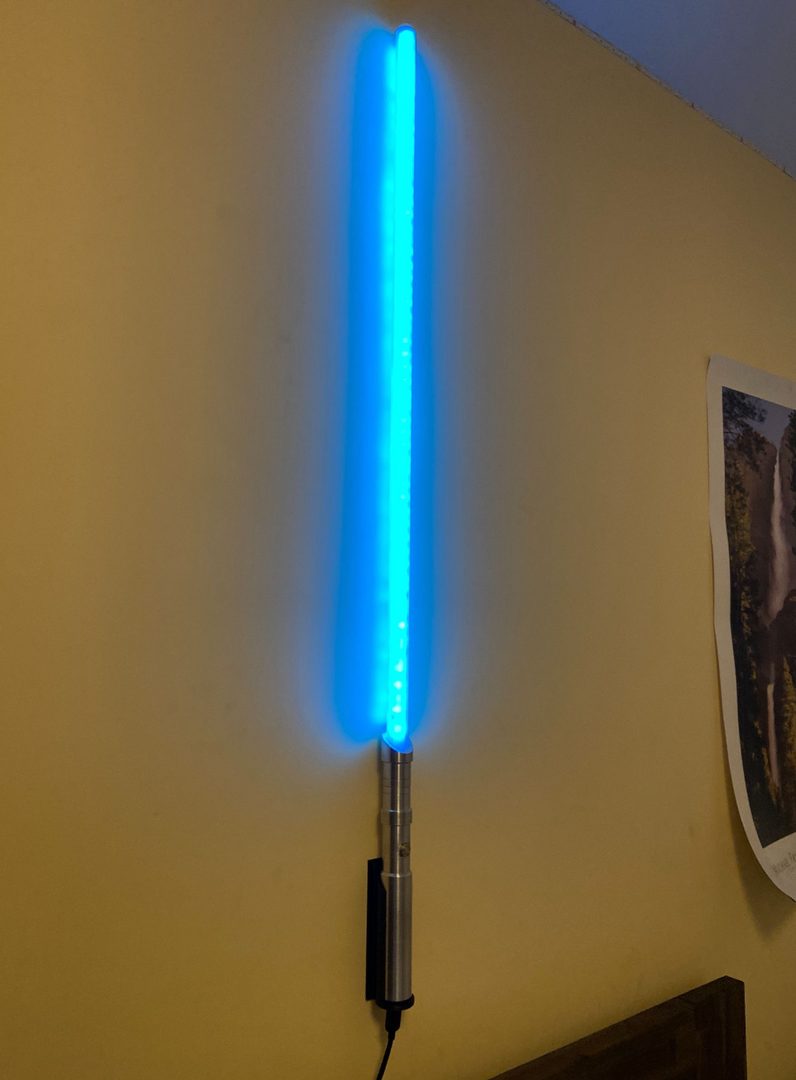
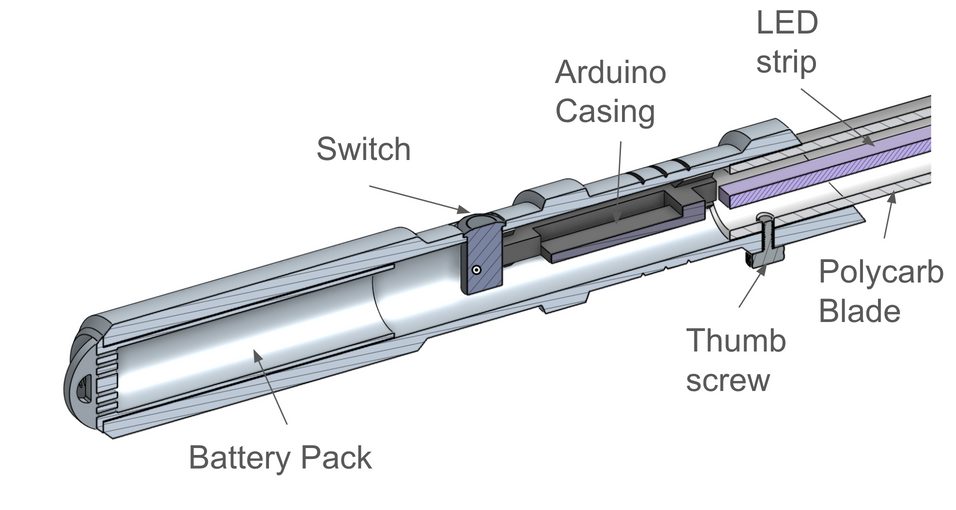
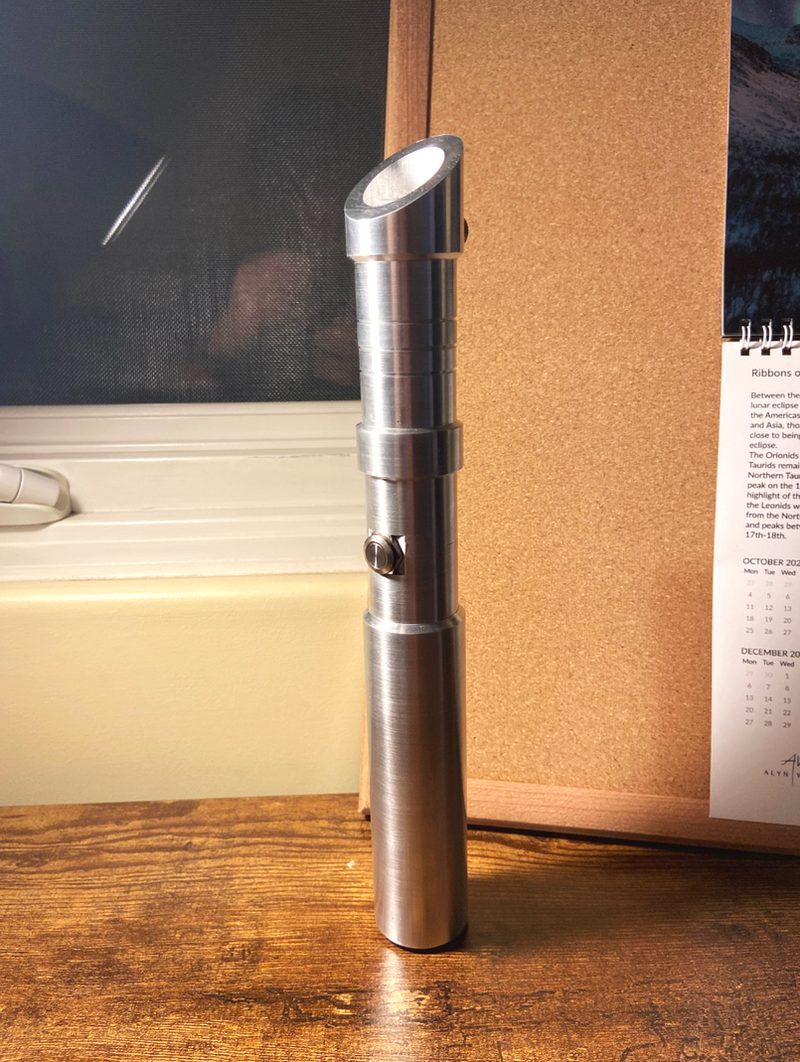
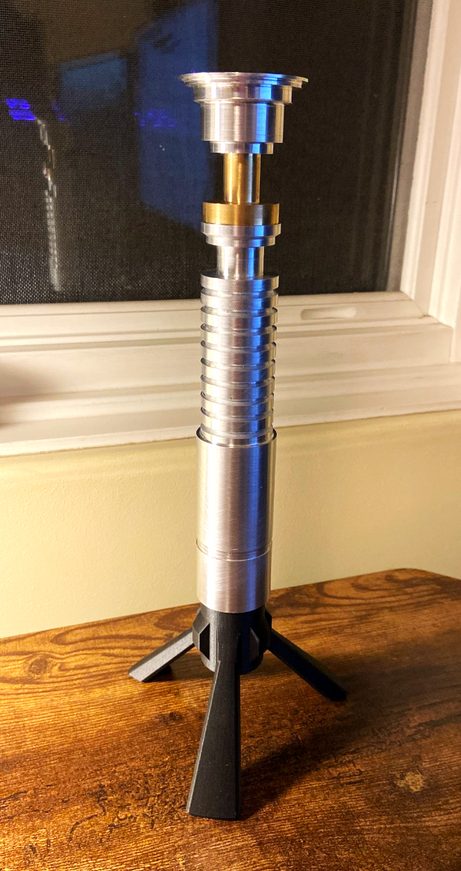
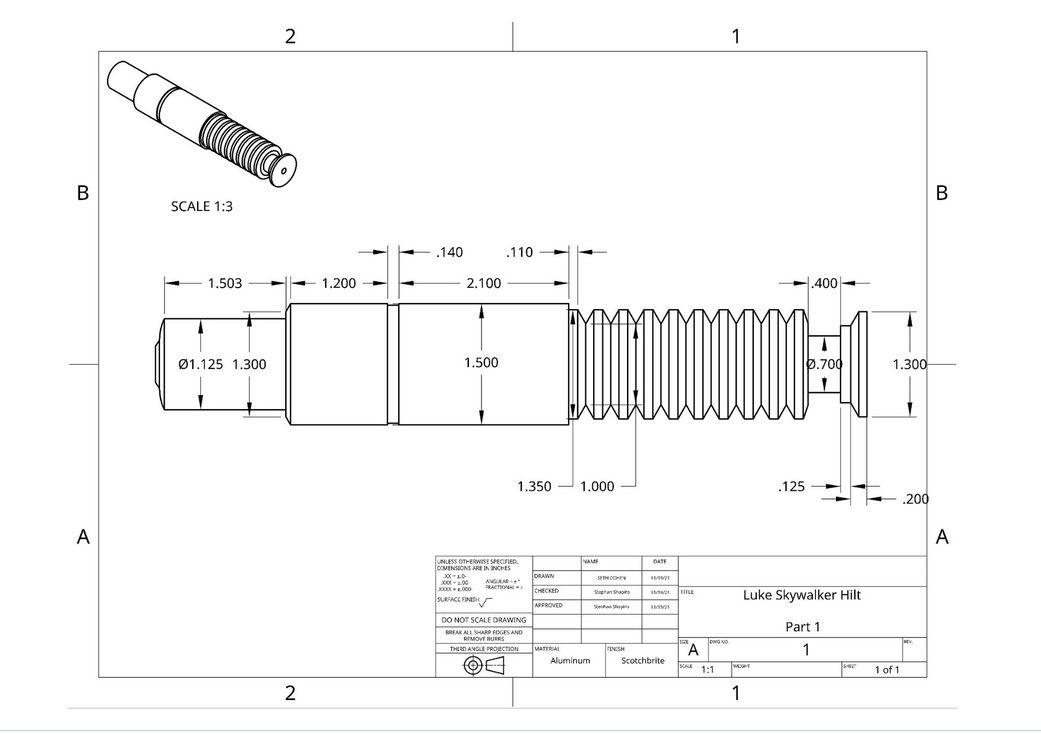
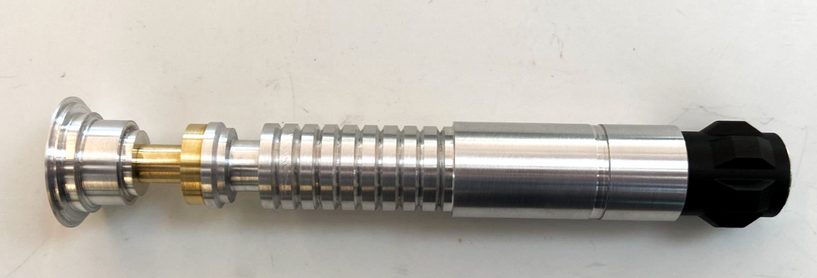
V2 is my own design, with an Arduino, an 18650 battery and an addressable RGB LED strip. V1 was a film-hilt replica designed to be made on a lathe, mill and 3D printer.
Award · December 2021
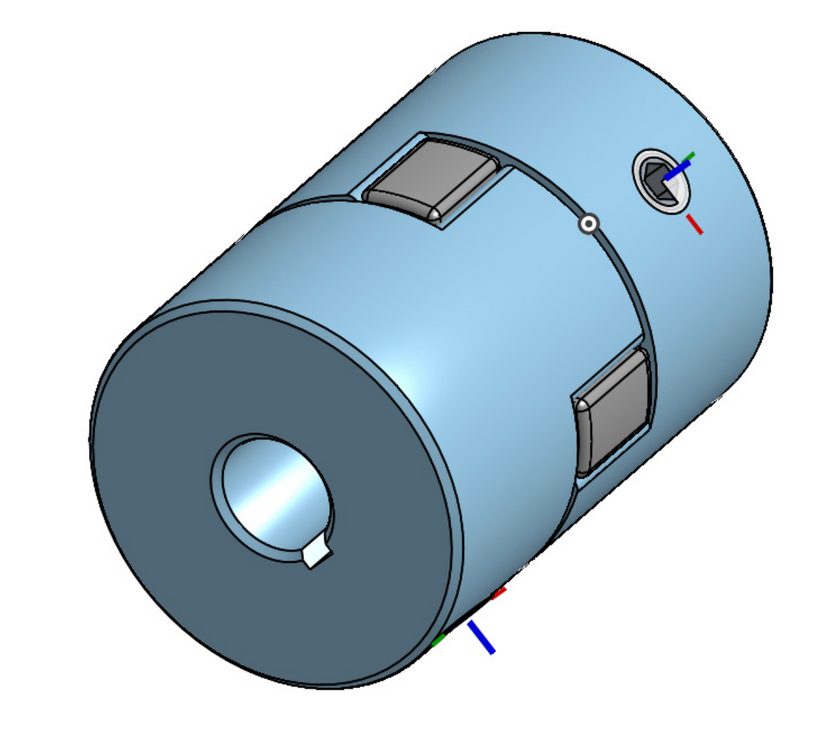
First place among 1,749 attempts, modeling a flexible shaft coupling in 2 min 44 s. Watch on YouTube
Personal build · high school graduation
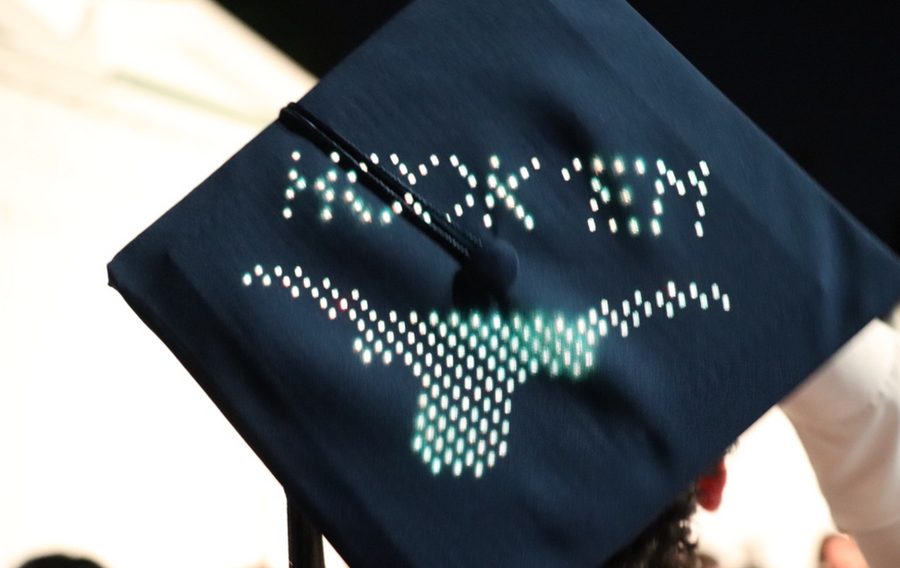
An Adafruit Feather runs C++ designs I wrote on an LED matrix, changing every 30 seconds.
All photos taken by me.
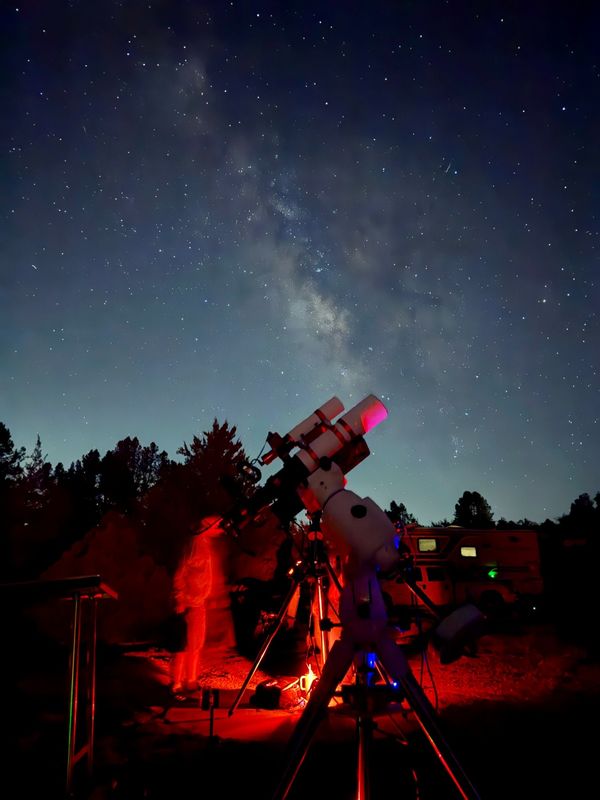
In the field
A refractor imaging setup under the Milky Way. Red light keeps eyes dark-adapted while the camera runs.